2 Location
A soil description is essentially useless without a confident location. Confidence is supported by clear communication about the measurement equipment used, the datum and coordinate reference system, the measurement units, and the expected error.
2.1 Absolute location
2.1.1 Recording location
Locations are recorded using a coordinate reference system (CRS), that defines a grid over the land surface. Geographical coordinate systems use angular coordinates (degrees latitude and longitude) and model the Earth as a sphere or ellipsoid. Projected coordinate systems, as implied by the name, project all or part of the Earth’s surface onto a flat plane by various methods, allowing the use of linear coordinates (e.g. metres).
Different types of projection have different strengths and weaknesses in terms of preserving distance, area, and direction accuracy. Elevation can also be determined from a global model, or a locally calibrated one.
In New Zealand the official projected coordinate reference system for the mainland and nearby islands is New Zealand Transverse Mercator 2000 (NZTM2000, EPSG:2193). Separate projections are available for outlying islands (e.g. the Chatham Island group) and parts of Antarctica. Elevation is defined with reference to New Zealand Vertical Datum 2016 (NZVD2016, EPSG:1169). For more information on these systems, see LINZ (2025a).
Location accuracy is largely a function of the equipment available and the quality of data recording (see Section 2.1.3). For soil survey work, location precision must be recorded to a minimum of 3 m but does not need to exceed 1 m for pits, or 0.1 m for cores and auger holes. Elevation precision will rarely need to exceed 0.1 m.
2.1.2 Expected error
Expected error can be automatically reported by equipment or estimated. When estimating horizontal error, record in metres with a maximum precision of 0.01 (1 cm) (e.g. ± 5.12 m). Record estimated vertical elevation error separately in the same units, because it will differ.
2.1.3 Equipment and data sources
Use a GNSS (Global Navigation Satellite System) with an expected horizontal accuracy of ±3 m or better. Some applications may require sub-metre or even centimetre accuracy. Sensor type can be recorded using one of the codes in Table 2.1.
| Code | Name | Description |
|---|---|---|
| GS | Single-band GNSS | Satellite-based location, single band |
| GM | Multi-band GNSS | Satellite-based location, multiple band |
| GR | Differential GNSS | Satellite-based location, on-ground correction |
| LM | Multi-sensor | Combined GNSS and other location data |
| NO | None | Location determined manually |
Parts of New Zealand still lack highly accurate elevation data. Recording the elevation measurement method using one of the codes in Table 2.2 below helps to provide an estimate of confidence in the elevation data.
| Code | Name | Description |
|---|---|---|
| D | DTM | Extracted from a high-accuracy Digital Terrain Model (DTM); e.g. LiDAR-based |
| G | GPS | Measured using a GNSS system with an adequate 3D fix |
| M | Map | Extracted from a low-accuracy DTM |
| A | Altimeter | Measured by a calibrated altimeter |
| E | Estimated | Estimated with reference to a nearby point of known elevation or from local knowledge |
D-type elevation measurements, (e.g. data extracted from high-resolution public datasets such as LINZ (2025b)), offer the best accuracy currently available in New Zealand, usually around ±0.2 m. Global, satellite-derived data sets, such as those available on Open Topography (https://opentopography.org), may offer comparable accuracy at a larger cell size and extend across some areas where lidar data are not yet available.
G-type elevation measurements are unlikely to be accurate if a GR-type sensor is not being used (see Section 2.1.3), and may require additional conversion to NZVD2016. However, some specialist GNSS systems can achieve elevation accuracies exceeding ±0.01 m.
The M code should be used for most non-lidar digital elevation models (DEMs), because those available for public use were constructed from interpolated contour data or other methods with comparable vertical accuracy (see Barringer et al. 2002; Uuemaa et al. 2020). M DEMs can be off by over 10 m in some areas, such as valley floors, where small landscape features are not captured (Barringer et al. 2002).
Where the A code is used, the time and location of the most recent altimeter calibration should be recorded. Hand-held altimeters can be expected to be accurate to within ±3 m.
E-estimated elevations might include interpolation from a contour map with an interval of >20 m, or a ‘best guess’.
2.2 Relative location
Absolute locations are enhanced by information on what is nearby. This context is useful for checking that a site’s coordinates are correct and for revisiting a site in future.
2.2.1 Triangulating off local features
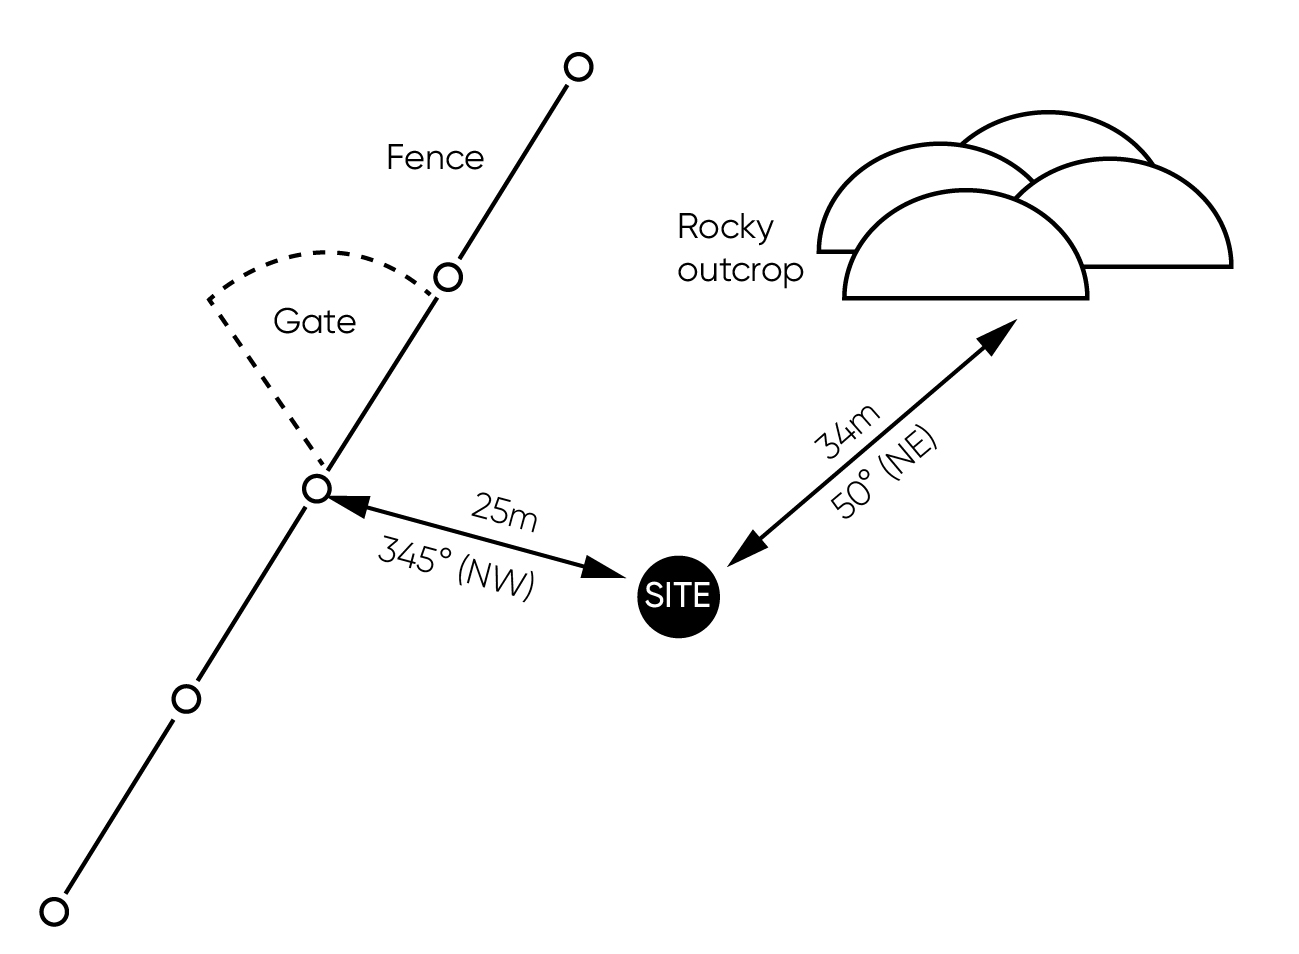
Absolute location data can be backed up by measuring to nearby permanent or long-term features. This practice is particularly useful for relocating long-term monitoring plots. For this to work well, features should be within ~50 m of the target location and sufficiently sturdy to last until at least the next expected visit. Examples include fencelines, buildings, roads, and rock outcrops.
For single-point sites, measure distance and direction using a tape and compass. Accuracy is improved by measuring to two or more features. For plot-based sites, measure from at least two corners to the target feature. Photographing the point/plot and reference points together is also useful (see Section B.3 for guidance on field photography).
2.2.2 Recording relative elevation
Elevation above the nearest down-slope drainage (open/flowing water, swampy ground, or a closed depression) is useful for landscape interpretations. The data can also be used to group profile descriptions; for instance, when identifying sets of related terraces along river systems. The drainage feature to record against must be identified by tracing a path down-slope from the observation point, and may be far away, so it will normally be more efficient to estimate this parameter after fieldwork using elevation and imagery data.
Record relative elevation in metres, with a precision of no more than 0.01 (1 cm) (e.g. 25.53 m).
2.2.3 Recording access details
For observation points that will be revisited, record practical information about how to return. This may include landholder contact details and records of previous interactions, notes about track conditions and locked gates, and potential hazards such as water crossings. Photographs of the site in the context of its surroundings can be helpful (see Section B.3). Spatial data recording the track from the nearest public road to the target location are particularly valuable.
2.2.4 Recording administrative location
Tagging sites with their administrative region(s) can help with discoverability (searching and filtering) in databases, and simplify information security and privacy arrangements. Tagging does not need to be done in the field provided accurate locations are recorded.
In New Zealand, relevant boundaries include regional council (Stats NZ 2023a) and territorial authority (district council, Stats NZ (2023b)) areas. Note that these boundaries are periodically updated so they need to be related to the date of observation.